Front bucket and pivot linkage form the working end for loading, grading and excavation.
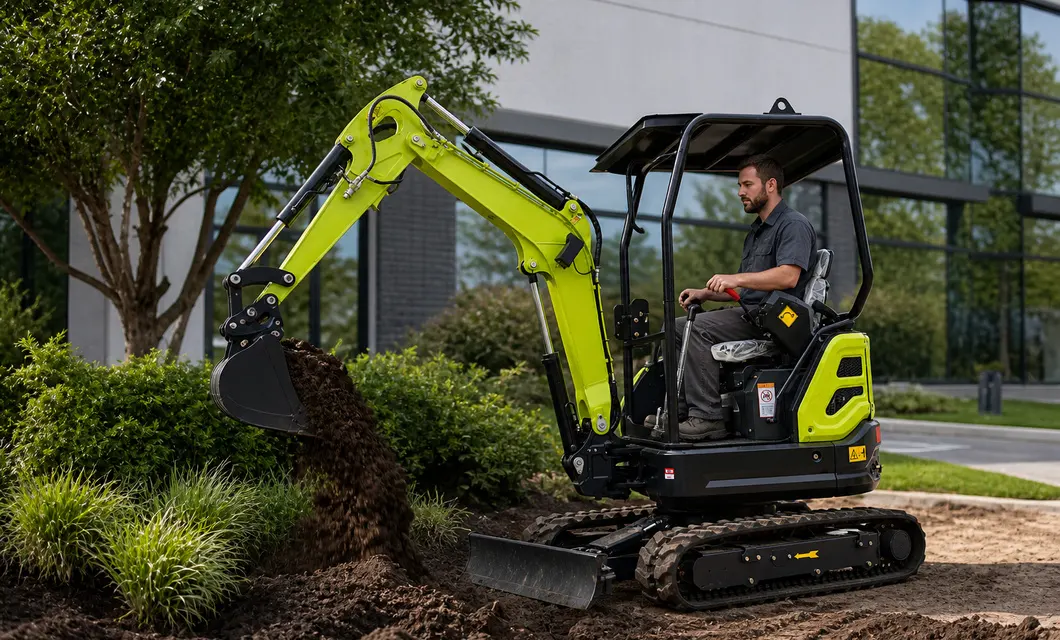 Utility Corridor Excavation
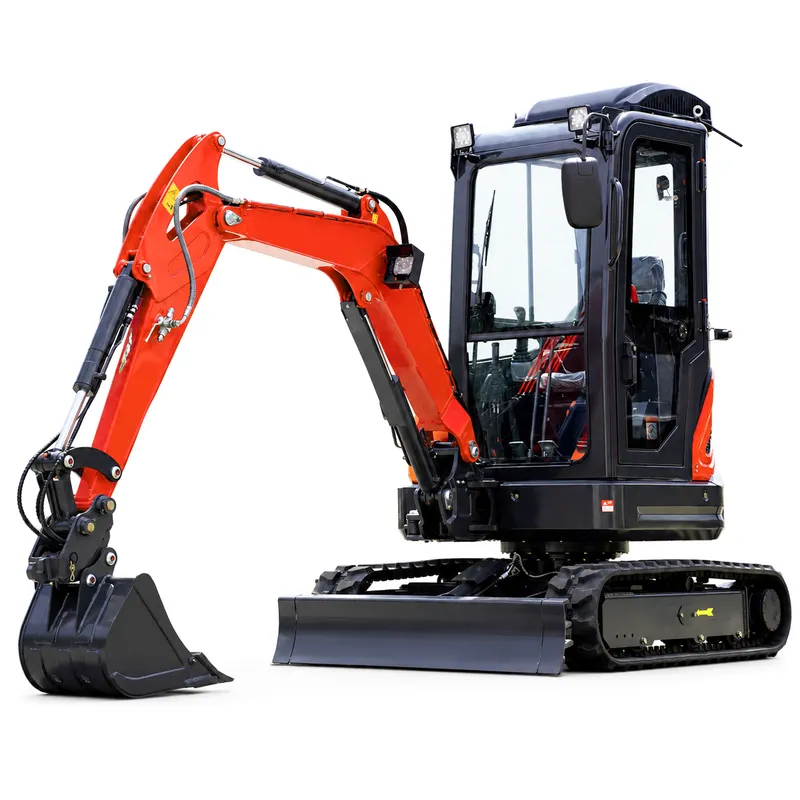
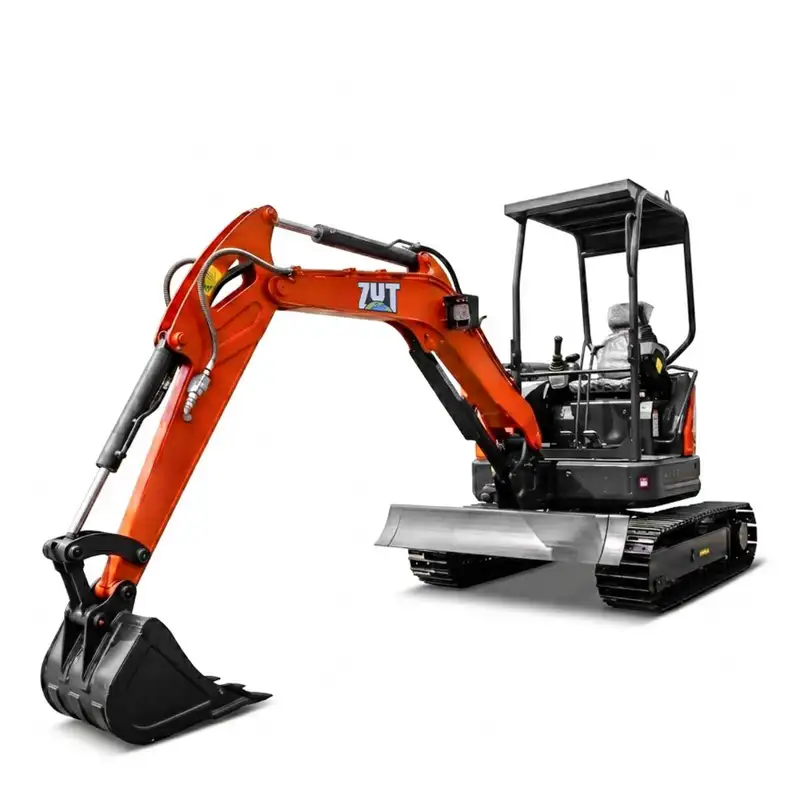
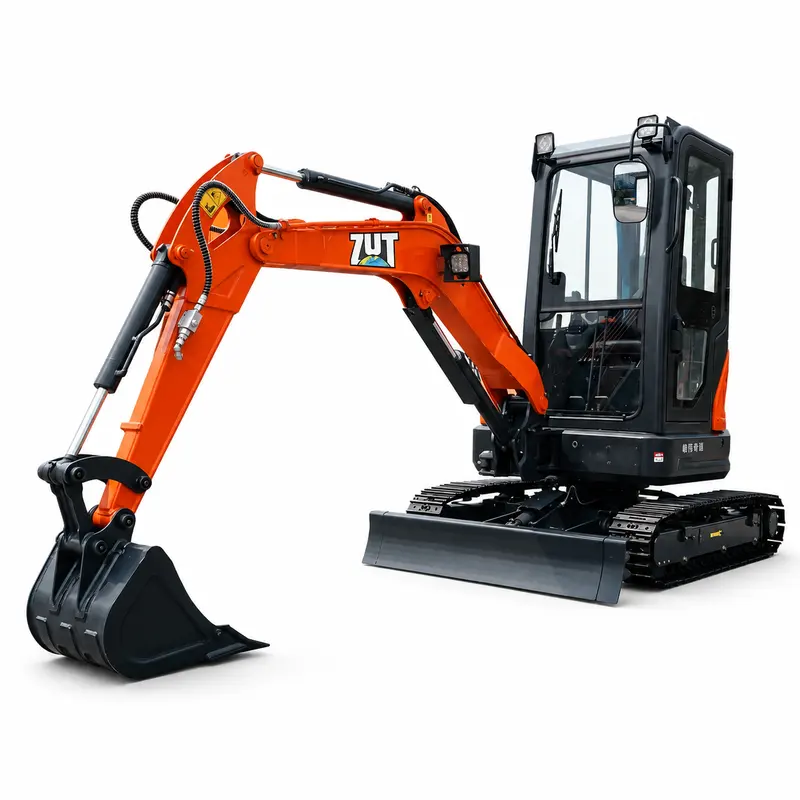
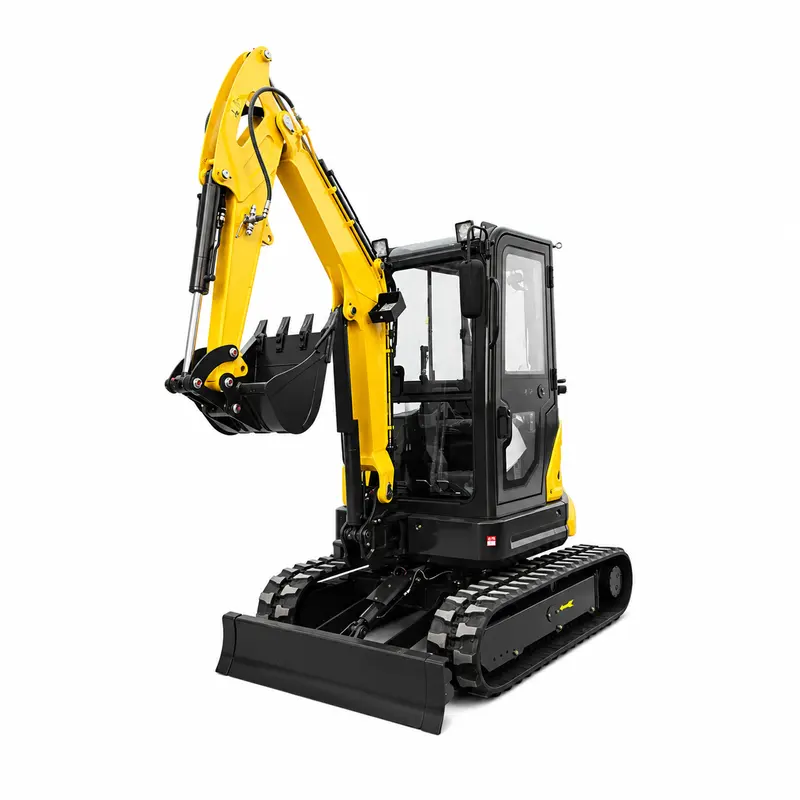
GW25 Mini Crawler Excavator
The four application scenes show controlled digging beside access roads, planting beds, service corridors and shallow foundation edges. In each setting, the tracked machine remains on stable ground while a seated operator uses the articulated arm and bucket to remove or place loose soil with close visibility around the work edge.
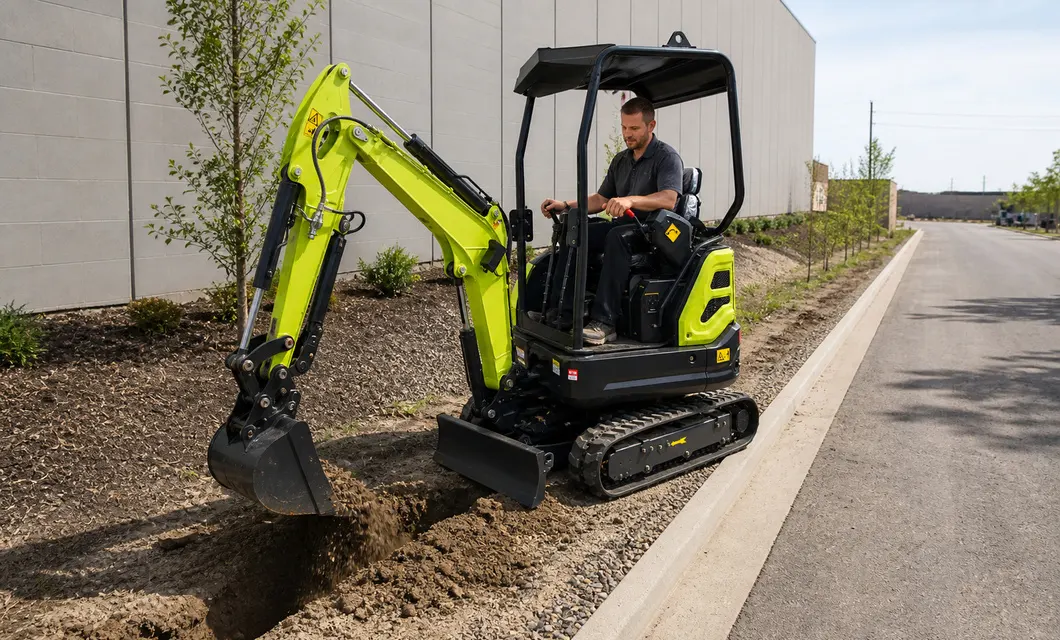 Clean Drainage Trenching
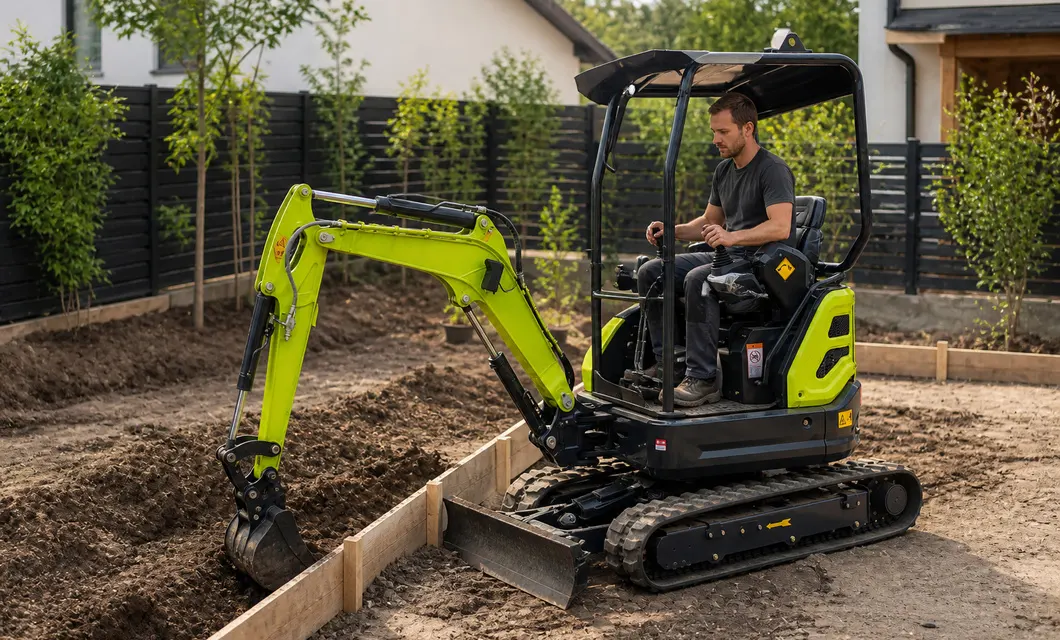 Landscape Soil ShapingUtility Corridor Excavation
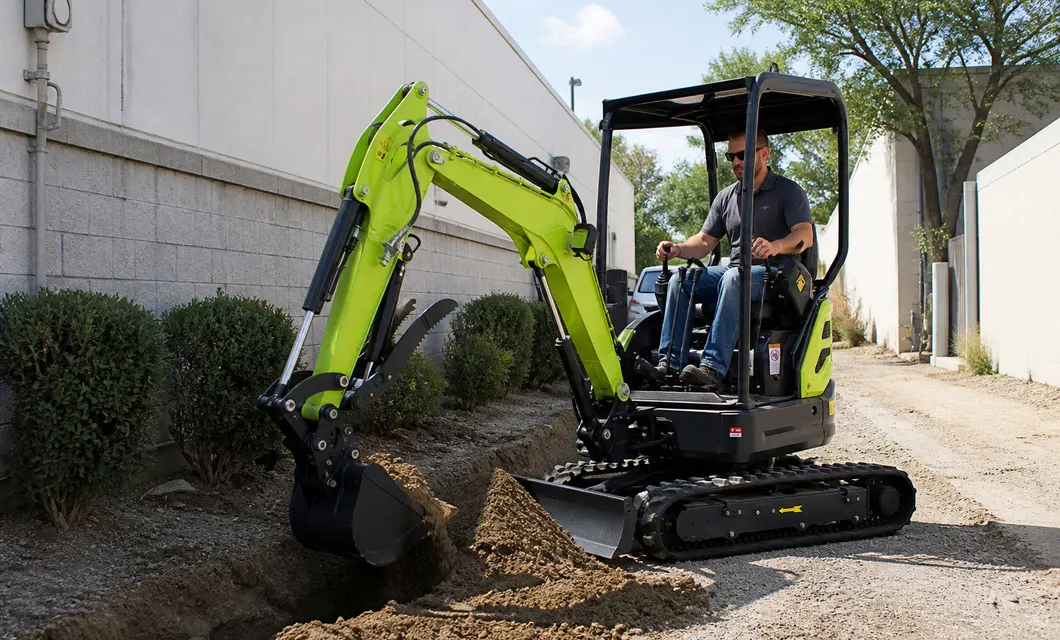 Foundation Edge ExcavationClean Drainage TrenchingLandscape Soil Shaping
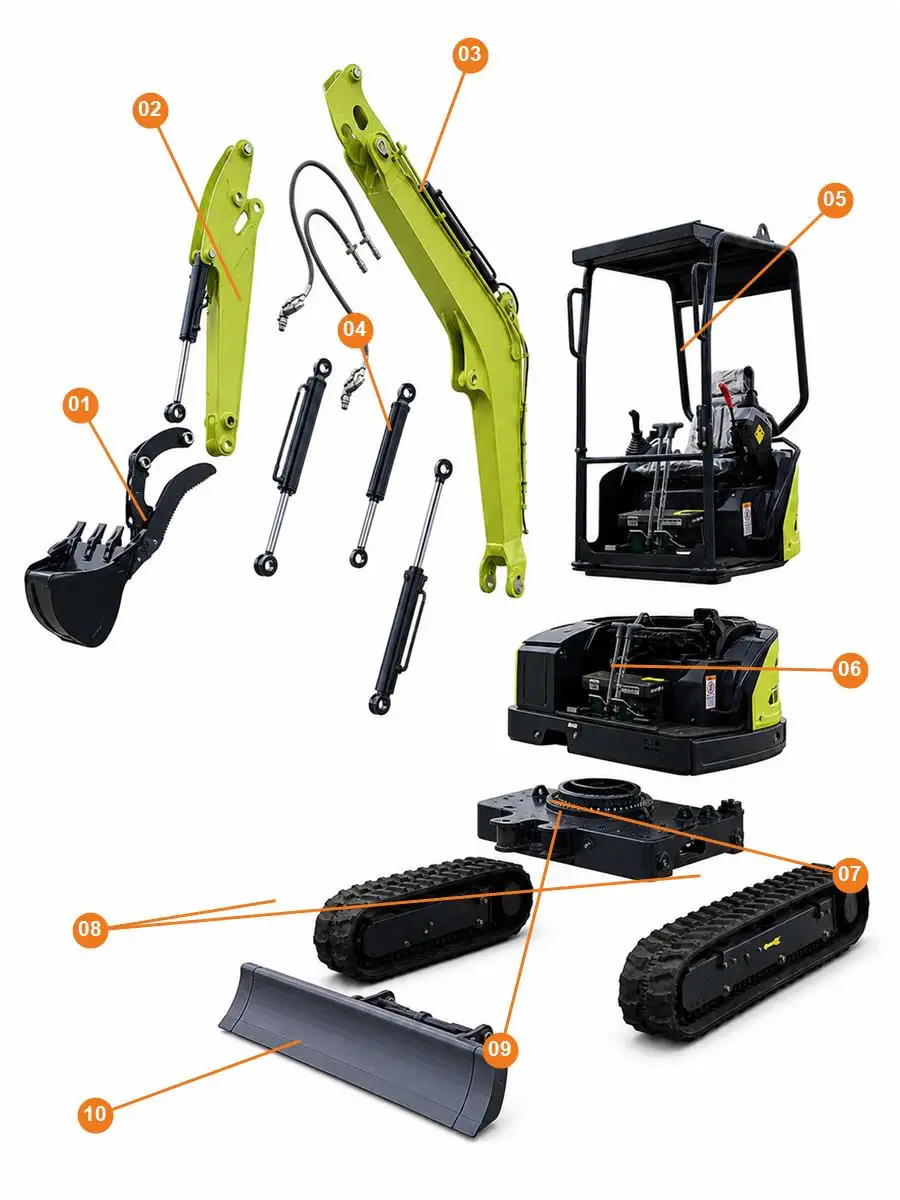
Front bucket and pivot linkage form the working end for loading, grading and excavation.
Green dipper arm carries bucket linkage and channels hydraulic force for controlled digging reach.
Main boom raises and positions the arm while retaining the front-facing machine orientation.
Exposed cylinders and hoses actuate boom, arm and bucket joints for coordinated movement.
Protective canopy, seat and controls form an open station with clear access and forward visibility.
Black upper body encloses visible equipment and balances the front attachment during digging.
Circular swing base joins upper body to lower frame and supports upper-structure rotation.
Qualification Documents
Our team is ready to advise you on the best product configuration and procurement plan.
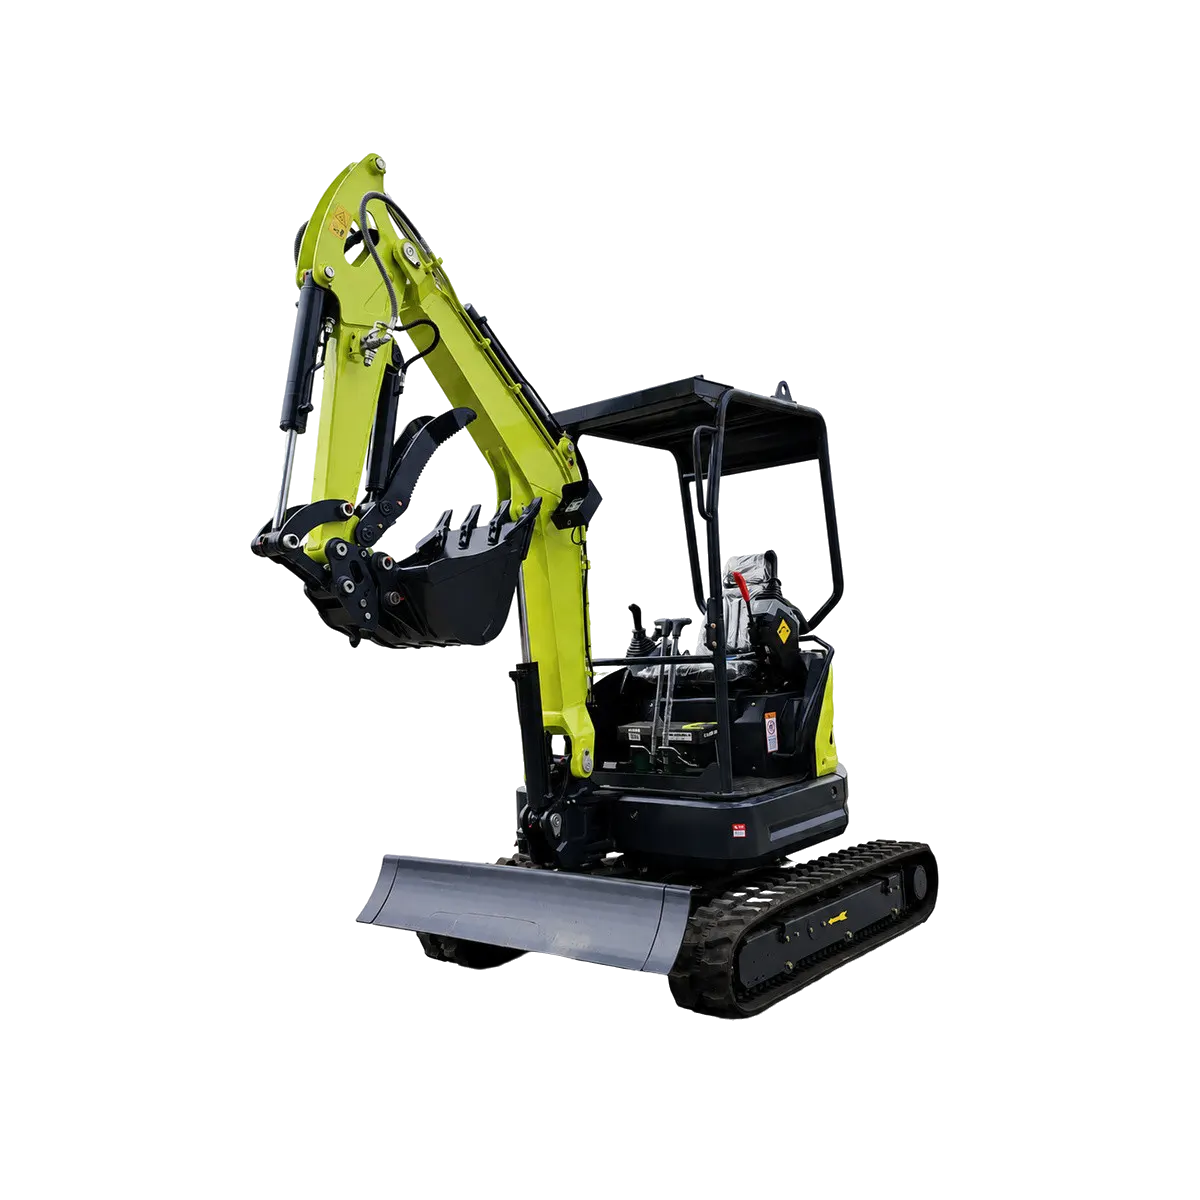
yiyunying2026@163.com400 158 5899It is suited to localized digging, soil shaping and shallow trench work where a compact tracked machine can be positioned close to the intended work edge.
The seated operator uses the visible hand controls to coordinate the articulated boom, dipper and bucket through their existing hydraulic pivot connections.
The tracked undercarriage provides broad ground contact, while the front blade can assist with orderly material grading and work-area setup.
The compact layout and clear operator sightline support careful placement near access roads, planting areas and other prepared outdoor surfaces.
Confirm the intended task, required access space, preferred configuration and the actual ground conditions so the machine can be matched to the planned work.

 Simplified explanation